Soulaimane Berkane
Control · Estimation · Robotics
Associate Professor
Department of Computer Science and Engineering
Université du Québec en Outaouais
Adjunct Professor, Lakehead University
Director, Robotics and Autonomous Systems Laboratory (LaRSA)
soulaimane.berkane@uqo.ca
Gatineau, Québec, Canada
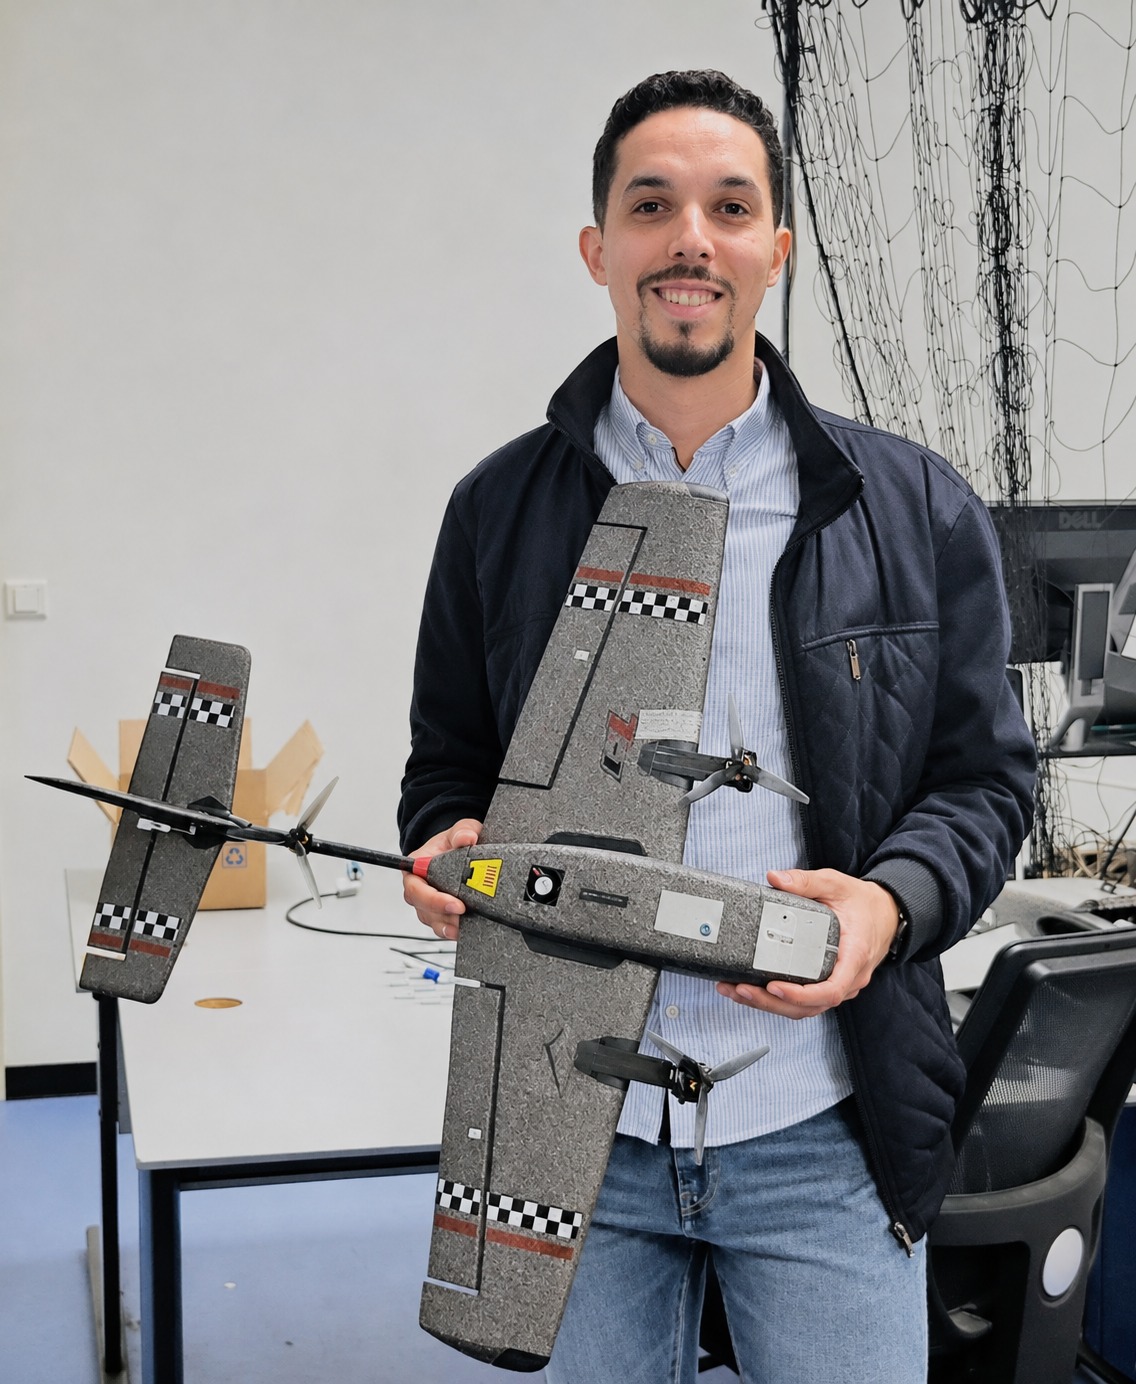
Soulaimane Berkane develops control and estimation methods for autonomous robots, with an emphasis on mathematical guarantees for stability, safety, and robustness.
His work connects nonlinear and geometric control with practical problems in navigation and sensing. Before joining UQO in 2019, he held postdoctoral appointments at KTH Royal Institute of Technology and Western University. He received his Ph.D. from Western University under the supervision of Abdelhamid Tayebi.
Research interests
- Nonlinear, geometric, and hybrid control
- State estimation and aided inertial navigation
- Safe motion planning and obstacle avoidance
- Multi-robot coordination and cooperative estimation
Selected work
- Tutorial on Aided Inertial Navigation Systems: A Modern Treatment Using Lie-Group Theoretical Methods
- A Geometric Observer for Visual-Inertial Odometry using Optical-Flow Constraints
- Safe and Quasi-Optimal Autonomous Navigation in Environments With Convex Obstacles
Professional service
Incoming Associate Editor, IEEE Control Systems Letters (2027–2029), and Associate Editor, IEEE Control Systems Society Conference Editorial Board (since 2021). Senior Member of the IEEE and Professional Engineer in Ontario.